Advancing Intelligent Robotics Through Learning and Control
Our lab develops both foundational theory and practical tools in machine learning and control to make robots more intelligent.
On the one hand, reinforcement learning provides a data-driven way for robots to learn decision-making policies through interaction. On the other hand, control theory offers rigorous, reliable design principles that guarantee stability and performance. By combining them, we enable robots to operate safely, autonomously, and efficiently in complex, real-world environments.
We are actively recruiting undergraduate and graduate students to join our team. Please see CONTACT for more information.
News and Updates
- [August 18, 2026] — We are excited to announce that the LC Lab has received a new $300,000 NSF award for the project “Integrating Physical Principles and Learning for Safe and Reliable Locomotion of Legged Robots.” Led by Dr. Leilei Cui, this project will advance our research at the intersection of learning, control, and legged robotics, with a focus on developing safe and reliable locomotion methods.
- [July 15, 2026] — We are excited to announce that the LC Lab has welcomed a new Unitree G1 humanoid robot! The robot will serve as an important experimental platform for our research in machine learning, control, and intelligent robotics.
Last updated: September 13, 2026
Highlights

Our Research
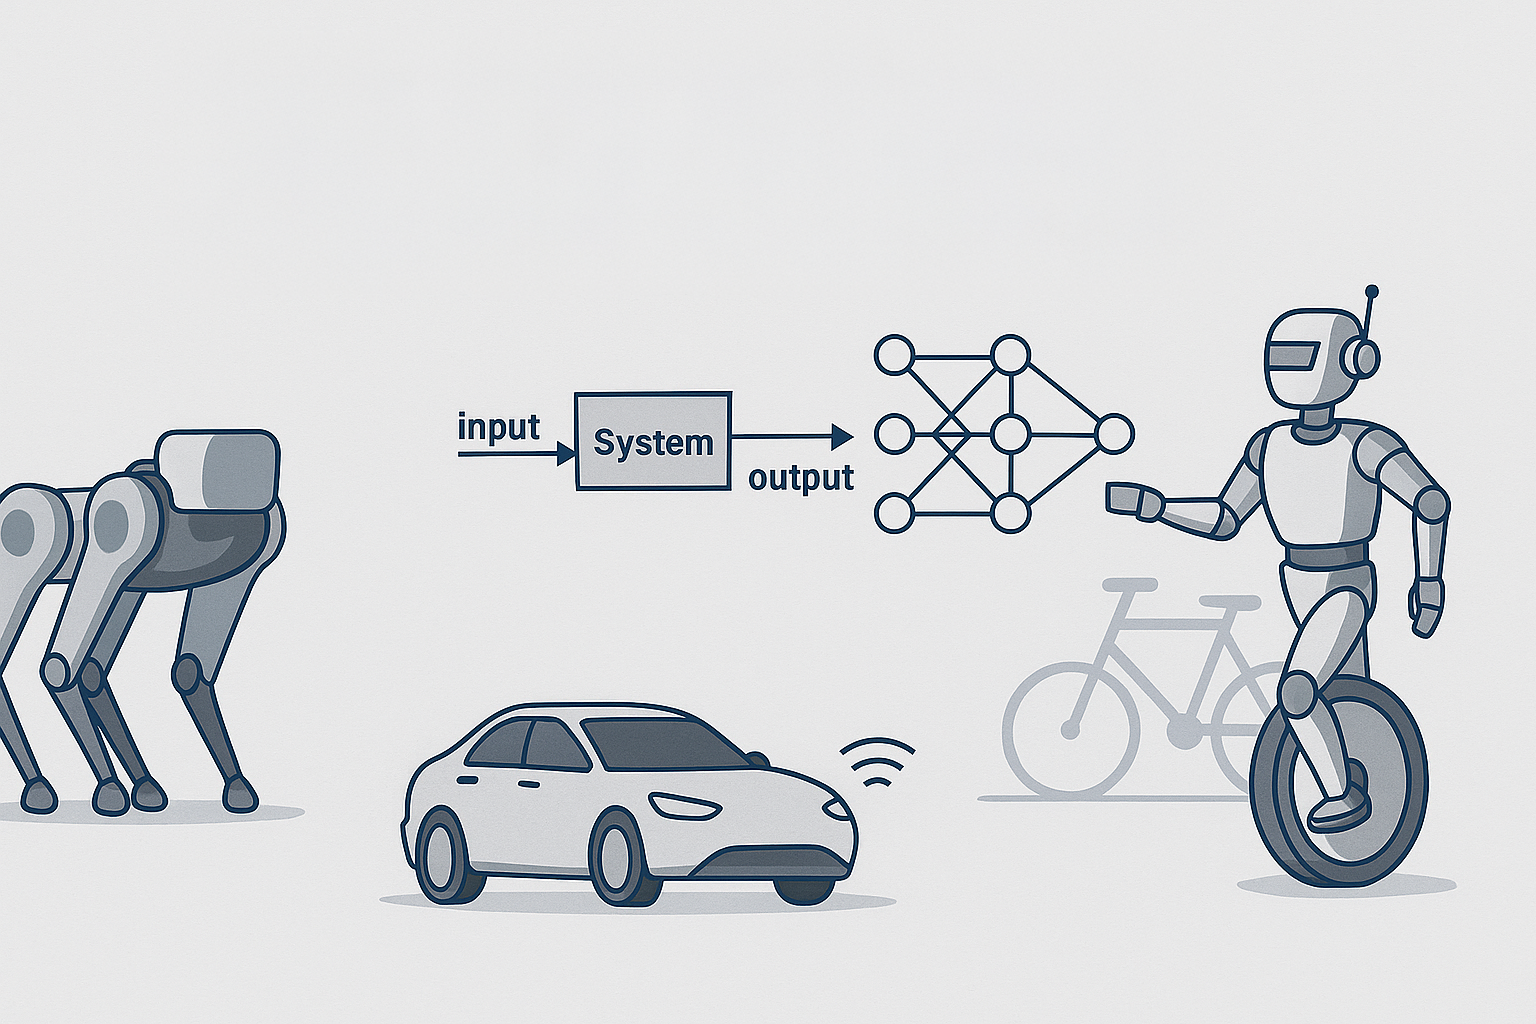
Our research can be broadly organized into three parts: learning for control, control for learning, and applications to robotics.
Our Teaching
We offer courses in the areas of dynamics & control and robotics.
Our Team
Our team includes researchers and graduate/undergraduate students passionate about learning and control and their applications to robotics.